The idea: search blind, but in a smart order
A search problem has a start state, a goal test, and actions that lead from one state to the next, each with a cost. An uninformed (blind) search knows nothing about where the goal is. It can only choose the order in which it tries paths. Two orders matter most before A*: cheapest path first, and shallowest path first with little memory.
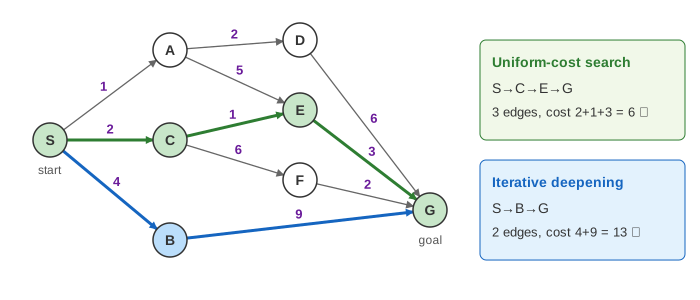
The canvas uses one directed graph with 8 nodes. S is the start and G the goal; the purple numbers are edge costs. Children are tried in alphabetical order. Pick a search and press Search, or run a demo. The table at the bottom keeps each search's result so you can compare them.
Uniform-cost search: cheapest first
Uniform-cost search (UCS) keeps a frontier of paths waiting to be extended, in a priority queue ordered by the path cost g(n). Each step it pops the entry with the lowest g and expands it: every child gets g + edge cost. A new child joins the frontier; a child already there is replaced only if the new path is cheaper. A node that was already expanded is skipped, because it was reached more cheaply before (Demo 1: uniform-cost search, cheapest first).
frontier = priority queue with (S, g = 0)
while frontier not empty:
    n = pop lowest g
    if n is the goal: return path to n
    mark n explored
    for each child c of n with edge cost w:
        if c not explored and (c not on frontier or g(n) + w < g(c)):
            put c on the frontier with g(c) = g(n) + w
This is Dijkstra's algorithm with an early stop at the goal. On the page's graph it pops S, A, C, D, E, B and then G, with cost 6. Two moments are worth watching. E first gets g = 6 through A, then C finds a path costing 3 and replaces it. G first gets g = 9 through D, then E finds 6.
Test for the goal when you pop, not when you push
When D is expanded, G is generated with g = 9. If the search stopped there, it would return S→A→D→G with cost 9 (Demo 2: goal test too early gives cost 9). The cheaper path through E was still on the frontier, behind entries with smaller g. Only when G comes off the queue is every other waiting path at least as expensive, so only then is its cost final. Breadth-first search may test at generation because there all edges cost the same.
Iterative deepening: deepen the limit, keep little
Depth-limited search is depth-first search that does not go below depth L. Iterative deepening DFS (IDDFS) runs it with L = 0, 1, 2, … until it finds the goal. Each round starts from scratch. The stack panel on the canvas holds only the current path, and a node is popped as soon as its children are done (Demo 3: iterative deepening, limits 0, 1, 2).
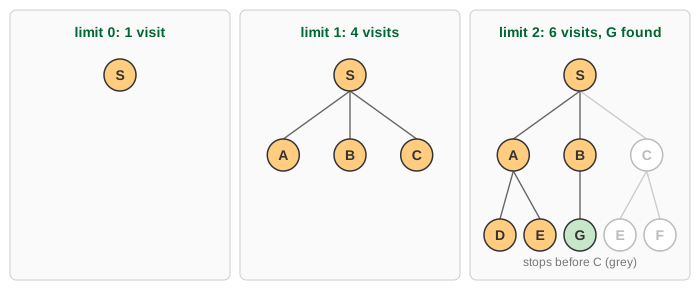
The repeated work is smaller than it looks. With branching factor b, the deepest level holds most of the nodes, so the upper levels searched again add only a constant factor: about b/(b − 1) times the work of a single search to that depth. In return, memory stays at the length of the path (times b if the siblings are stored).
IDDFS returns the goal with the fewest edges, like breadth-first search. It ignores costs, so on this graph it finds S→B→G with cost 13. Set edge costs to all 1 and both searches return S→B→G with cost 2: when every step costs the same, uniform-cost search expands nodes in the same order as BFS (Demo 5: all costs 1).
Side by side
Demo 4: UCS vs IDDFS fills the table with both runs: UCS visits 7 nodes but keeps up to 8 in memory (the whole graph), while IDDFS visits 11 and never keeps more than 3.
| uniform-cost search | iterative deepening DFS | |
|---|---|---|
| order | lowest path cost g first | depth first, limit 0, 1, 2, … |
| complete? | yes, if every cost ≥ some ε > 0 | yes, on a finite branching factor |
| optimal? | yes, cheapest path | fewest edges only (cheapest when all costs are equal) |
| time | O(b1 + ⌊C*/ε⌋) | O(bd) |
| memory | O(b1 + ⌊C*/ε⌋): frontier and explored set | O(b·d): the current path |
| on this graph | S→C→E→G, cost 6, 7 visits, peak 8 nodes | S→B→G, cost 13, 11 visits, peak 3 nodes |
Here C* is the cost of the best path, ε the smallest edge cost and d the depth of the shallowest goal. A* keeps the UCS frontier but orders it by g + h, adding a guess h of the remaining cost; IDA* does the same trick for iterative deepening, with a cost limit instead of a depth limit.
See also BFS vs DFS for the two plain orders, Dijkstra's algorithm for the same cost order over a whole graph, A* Search for what a heuristic adds, and Minimax, where game engines use iterative deepening.
What the page leaves out
Graphs with cycles (IDDFS then checks the current path, UCS the explored set); bidirectional search; depth-limited search on its own; iterative lengthening (a cost limit instead of a depth limit); IDA* and other informed searches; tie-breaking rules beyond first in, first out.
See where this page fits on the AI: Search, Games & Reasoning mind map.